Safe and Efficient Navigation Considering Texting Pedestrians via Attention-Aware Cost-map Tuning
Abstract
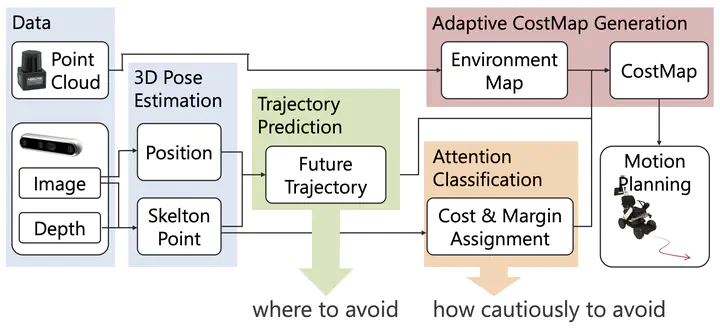
Smartphone-distracted pedestrians deviate from social norms unpredictably and cannot be relied upon to yield to approaching robots — a safety challenge that existing navigation methods are poorly equipped to handle, since they treat all pedestrians uniformly regardless of attention state. We propose an attention-aware navigation framework that classifies each pedestrian as attentive or distracted in real-time using 3D skeletal features and a Random Forest classifier, then dynamically widens cost-map safety margins around distracted individuals to drive proactive avoidance. A within-subjects user study with 12 participants across 252 trials demonstrates significant improvements in perceived smoothness (p = 0.003) and predictability (p = 0.034) over both a LiDAR-only baseline and a trajectory-prediction-only method, without any increase in travel time. Notably, trajectory prediction alone does not improve subjective navigation quality unless coupled with attention-state-aware cost adjustment — confirming that appropriately responding to who is in front of the robot can matter more than trajectory smoothness alone.